Open robotics lab Challenges open
Robots learn
from people.
Neotics is an open lab for robot skills. Build and teach them, have them judged in the open, and keep your name on every one.
- 01A robot hand closes in an instant.
- 02Knowing when, and how gently, has to be shown.
- 03Someone shows it. Neotics keeps their name on it.
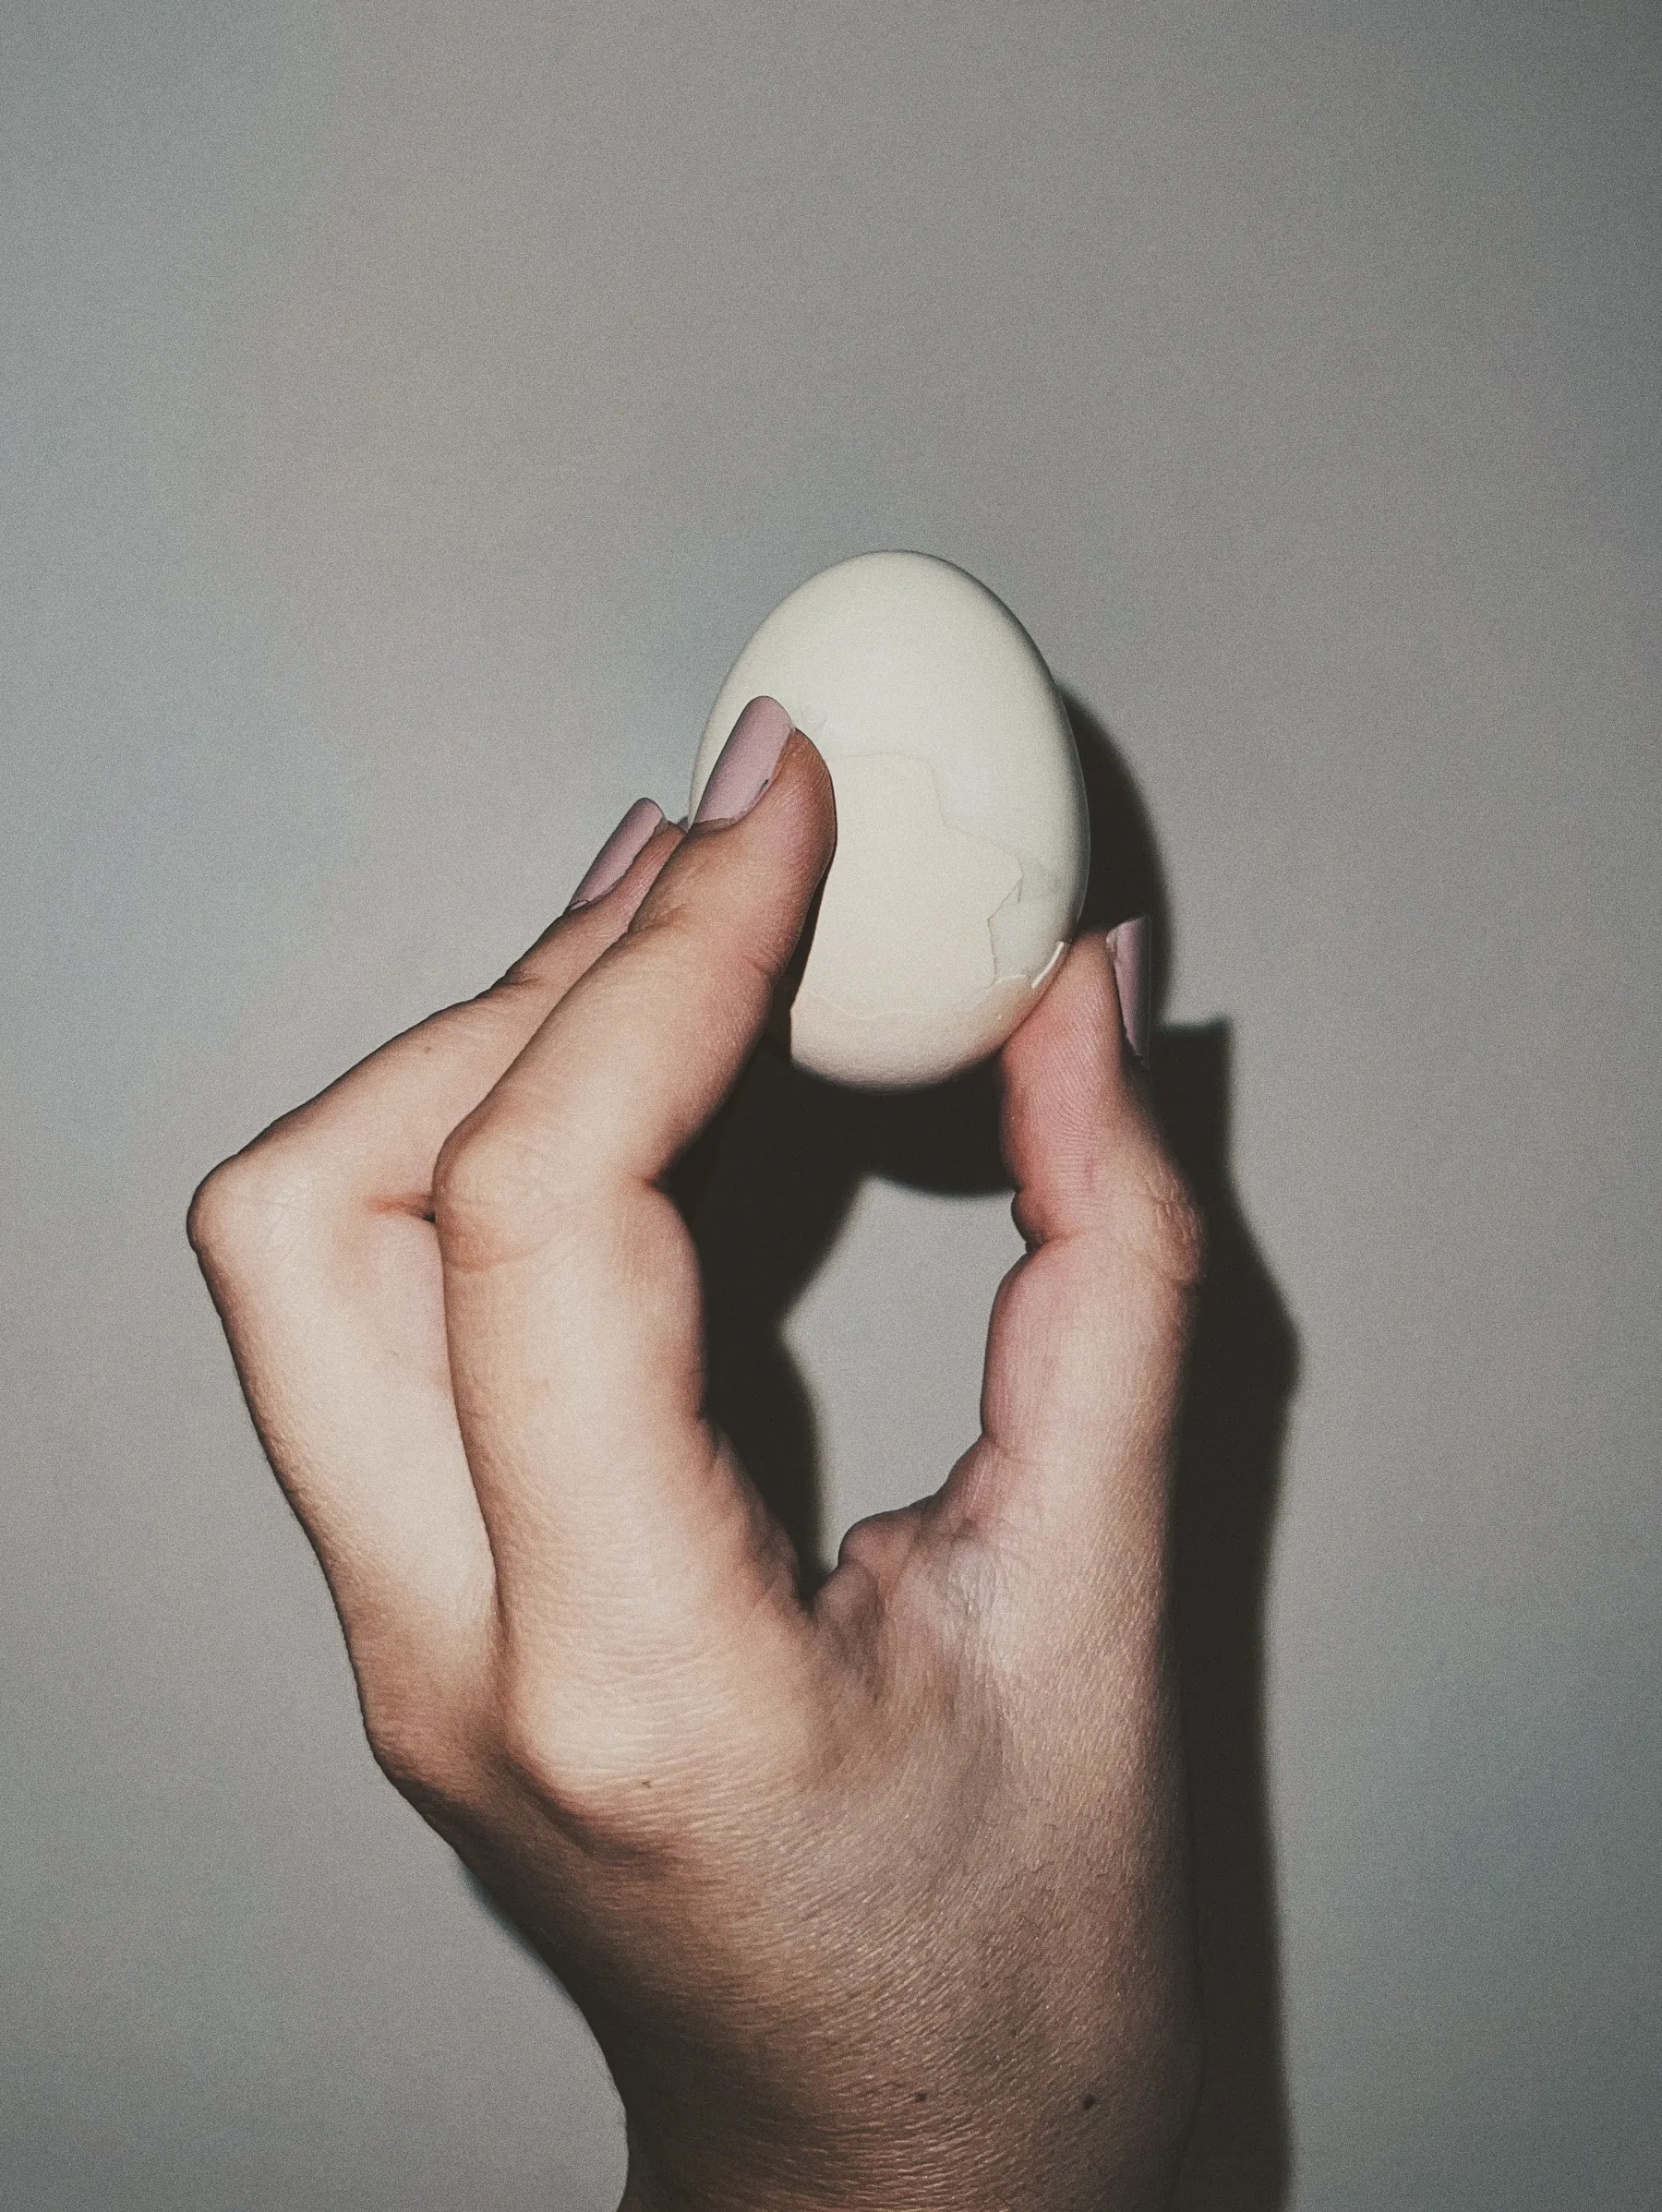
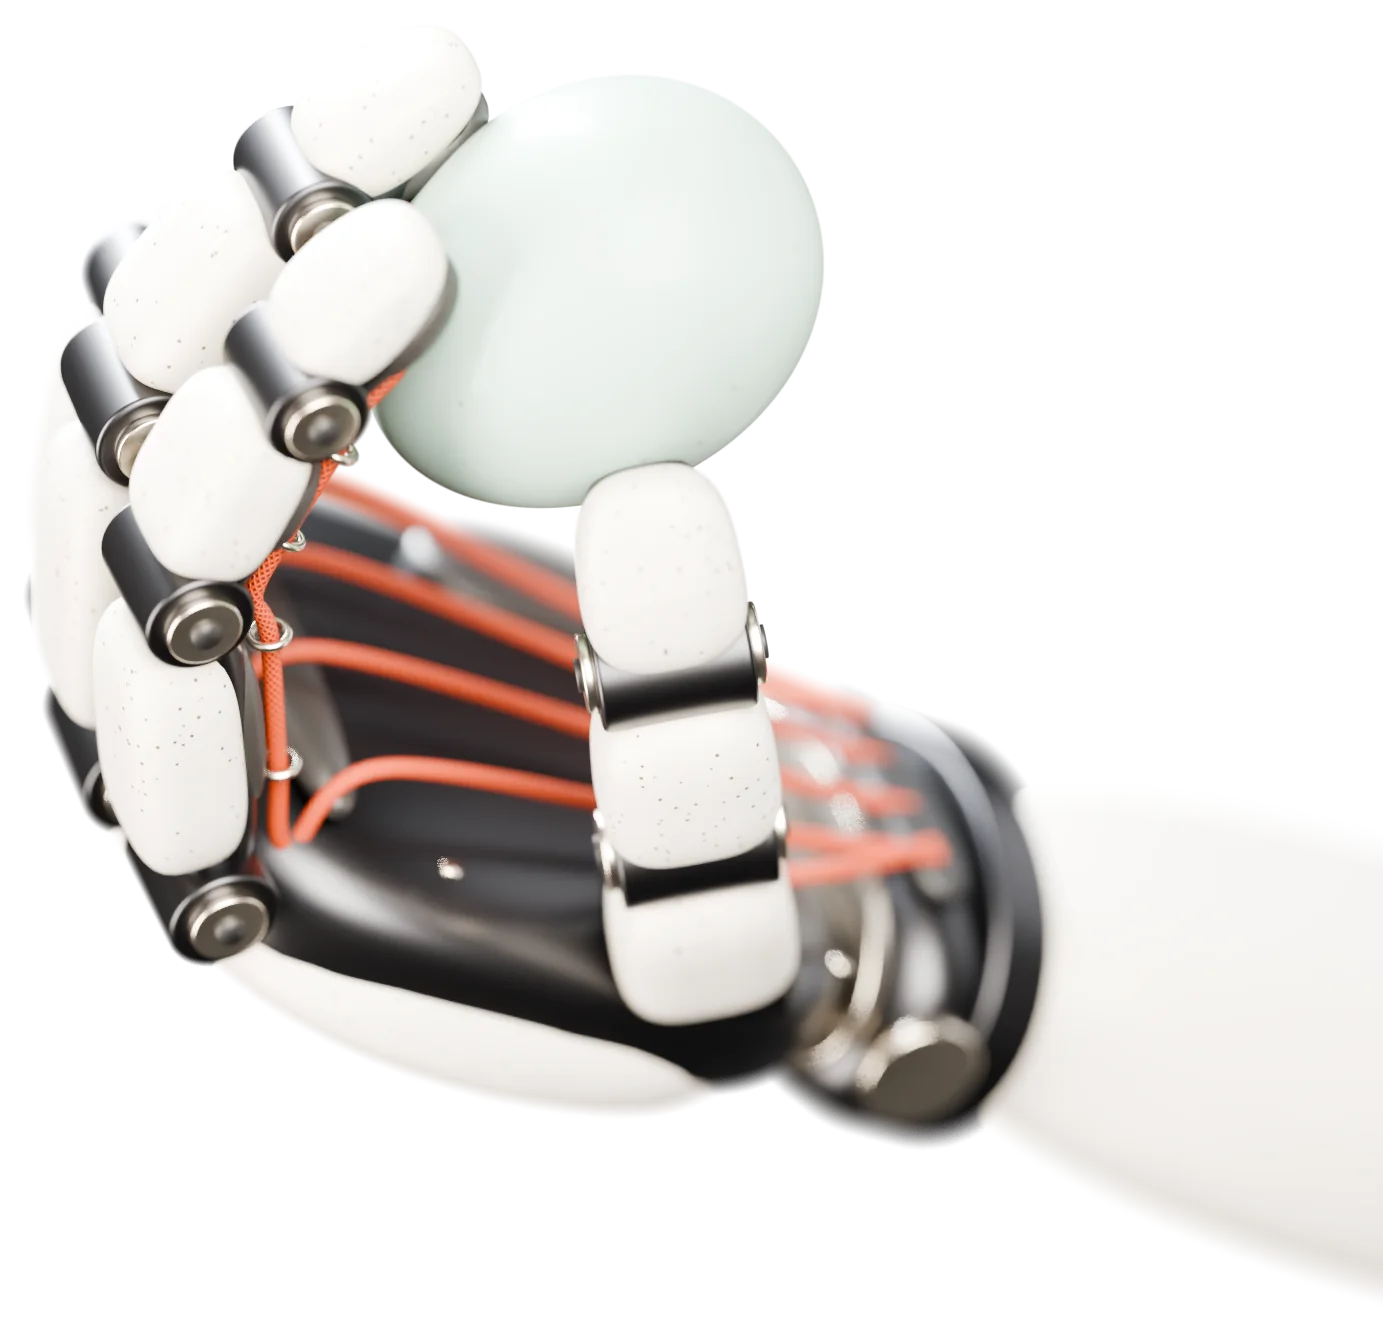
Every gentle grip was shown by someone first.
A robot hand can close in an instant. How firmly, how slowly and when to let go come from people who already know.
01 · The idea
The strength between the parts.
In a body, sinew carries force from muscle to bone. In robotics, that is people: the ones who write the code, record the demonstrations, build the simulated worlds and check the results.
Neotics is new robotics: people show, robots learn, and the lab keeps their names on the work.
- CodePolicies, planners, drivers
- DemonstrationsRecorded attempts a robot learns from
- WorldsSimulated rooms, objects and tasks
- BenchmarksEvaluation packs that keep scores honest
02 · How it works
From a challenge to a skill a robot can use.
-
01
Pick a challenge
Challenges come in tracks: Basics to start, Proto and Research to go deeper, Enterprise when a company funds the prize.
Open · first challenges soon
-
02
Build it
Write the code, record the demonstrations, design the world. Studio, a physics simulator that runs in the browser, is on its way.
Studio in development
-
03
Get judged in the open
Every entry is scored by automated benchmarks and reviewed by the community. Scores and licences are public.
How every challenge works
-
04
Keep your name on it
Accepted work goes into a shared library with its makers credited. When others use it, its makers are paid.
Library and royalties planned
 Twist · 1.9 s
Close · 1.2 s
Reach · 0.0 s
Reach, close, twist.
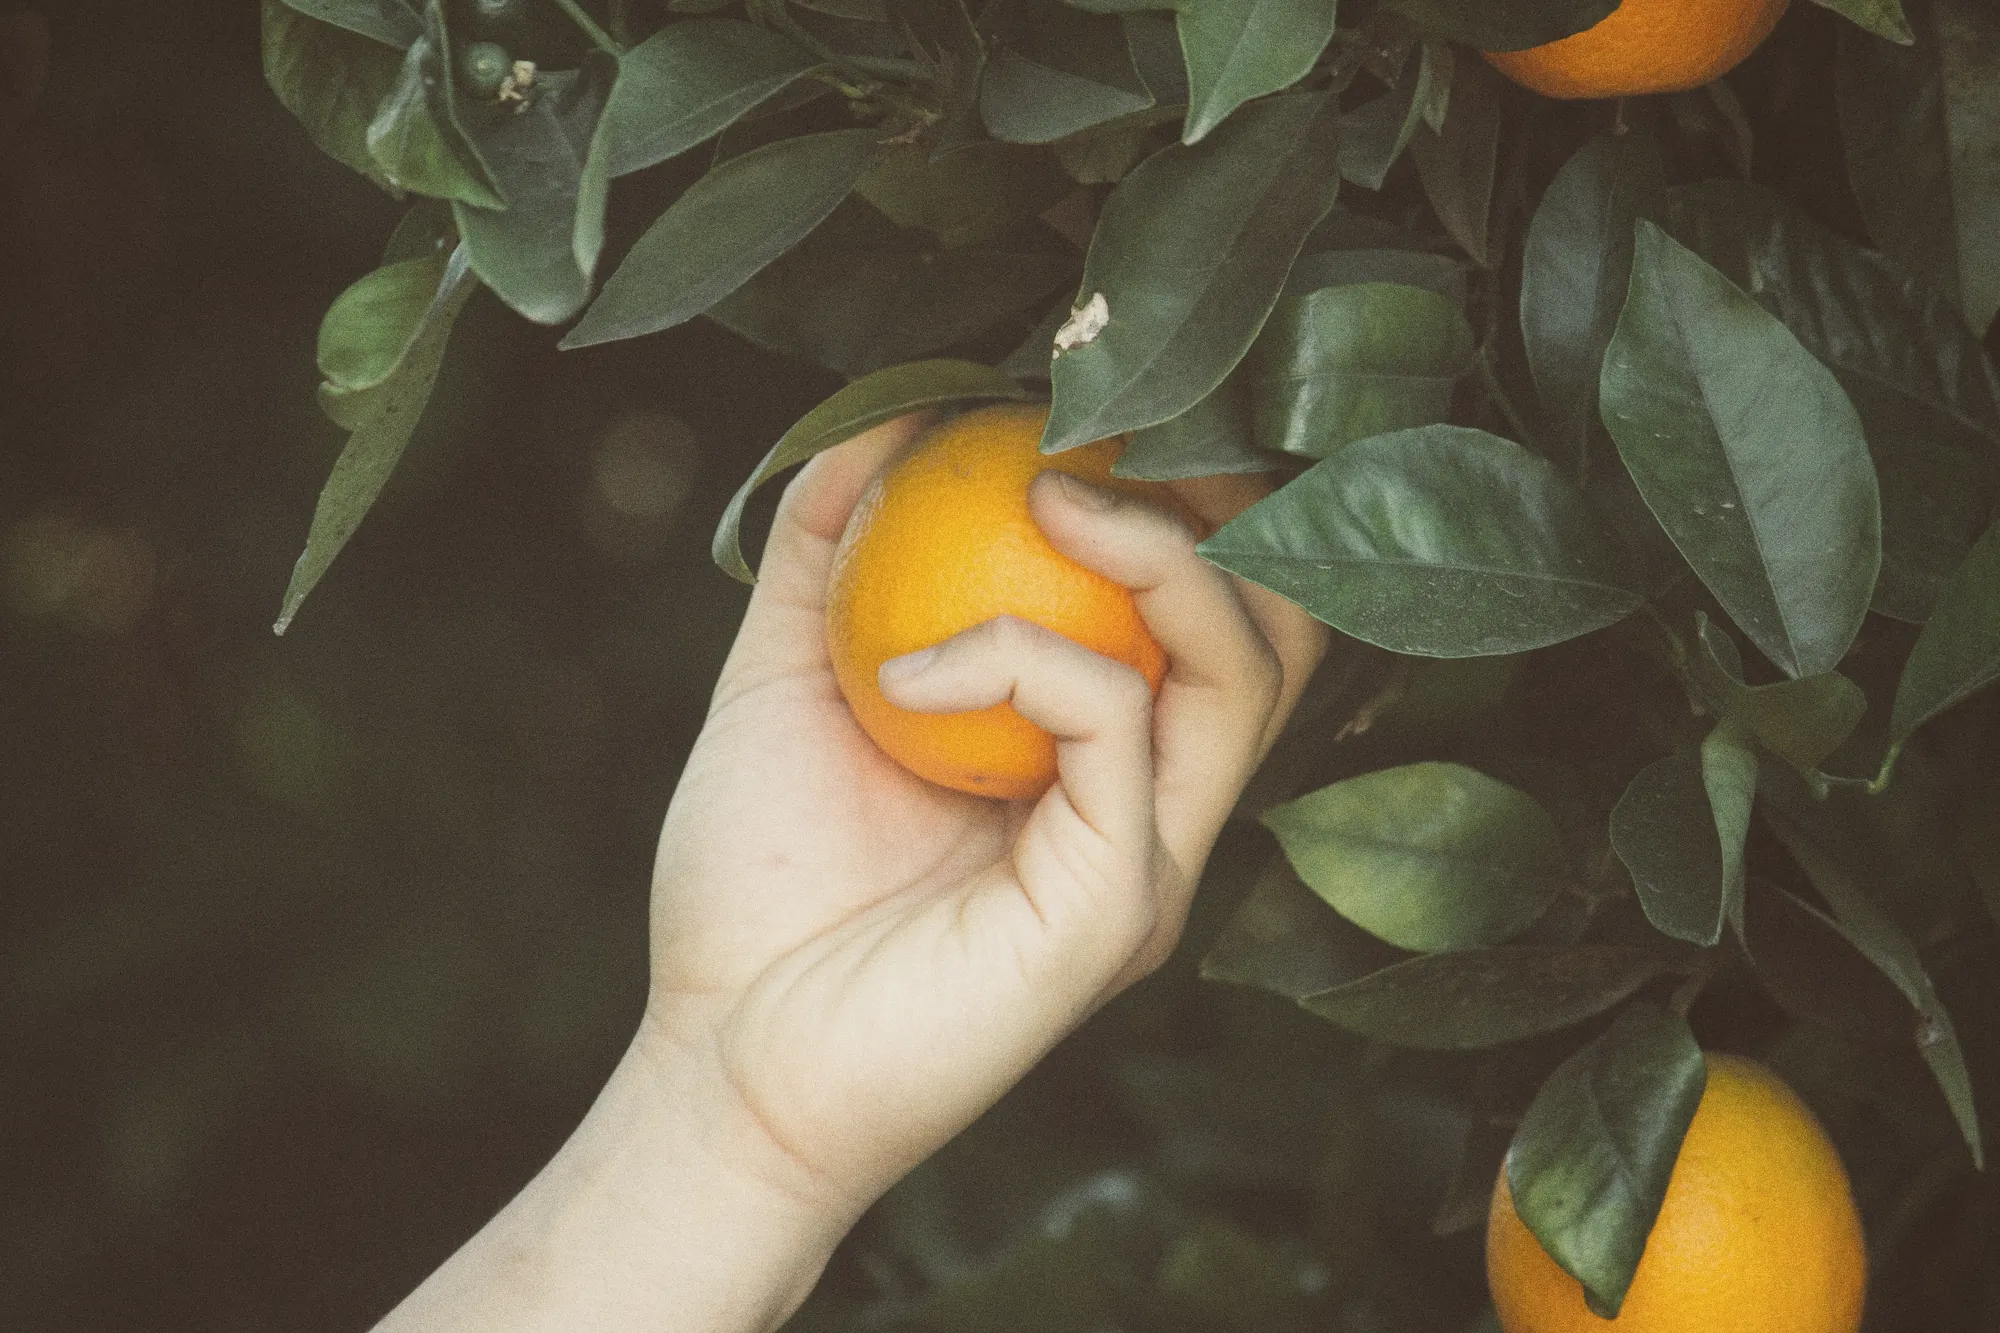
Picking fruit without bruising it takes a person two seconds and no thought. A robot has to be shown, and a recorded demonstration is how: one path, signed by whoever made it.
Every demonstration is a line.
A robot learns a grip from many people showing it, one attempt at a time. On Neotics, every attempt is signed.
Each line is one demonstration. The orange one could be yours.
03 · Open by default
Every part, open.
Neotics is built on ten open-source projects and works in the open: licences, benchmarks and scores are public, and the code goes on GitHub at launch.
- ROS 2Robot middleware
- MoveIt 2Motion planning
- Nav2Navigation
- Gazebo SimSimulation
- MuJoCoPhysics
- GenesisPhysics and rendering
- LeRobotLearning from demonstrations
- ZenohMessaging
- OpenUSDScene description
- Open-RMFFleets
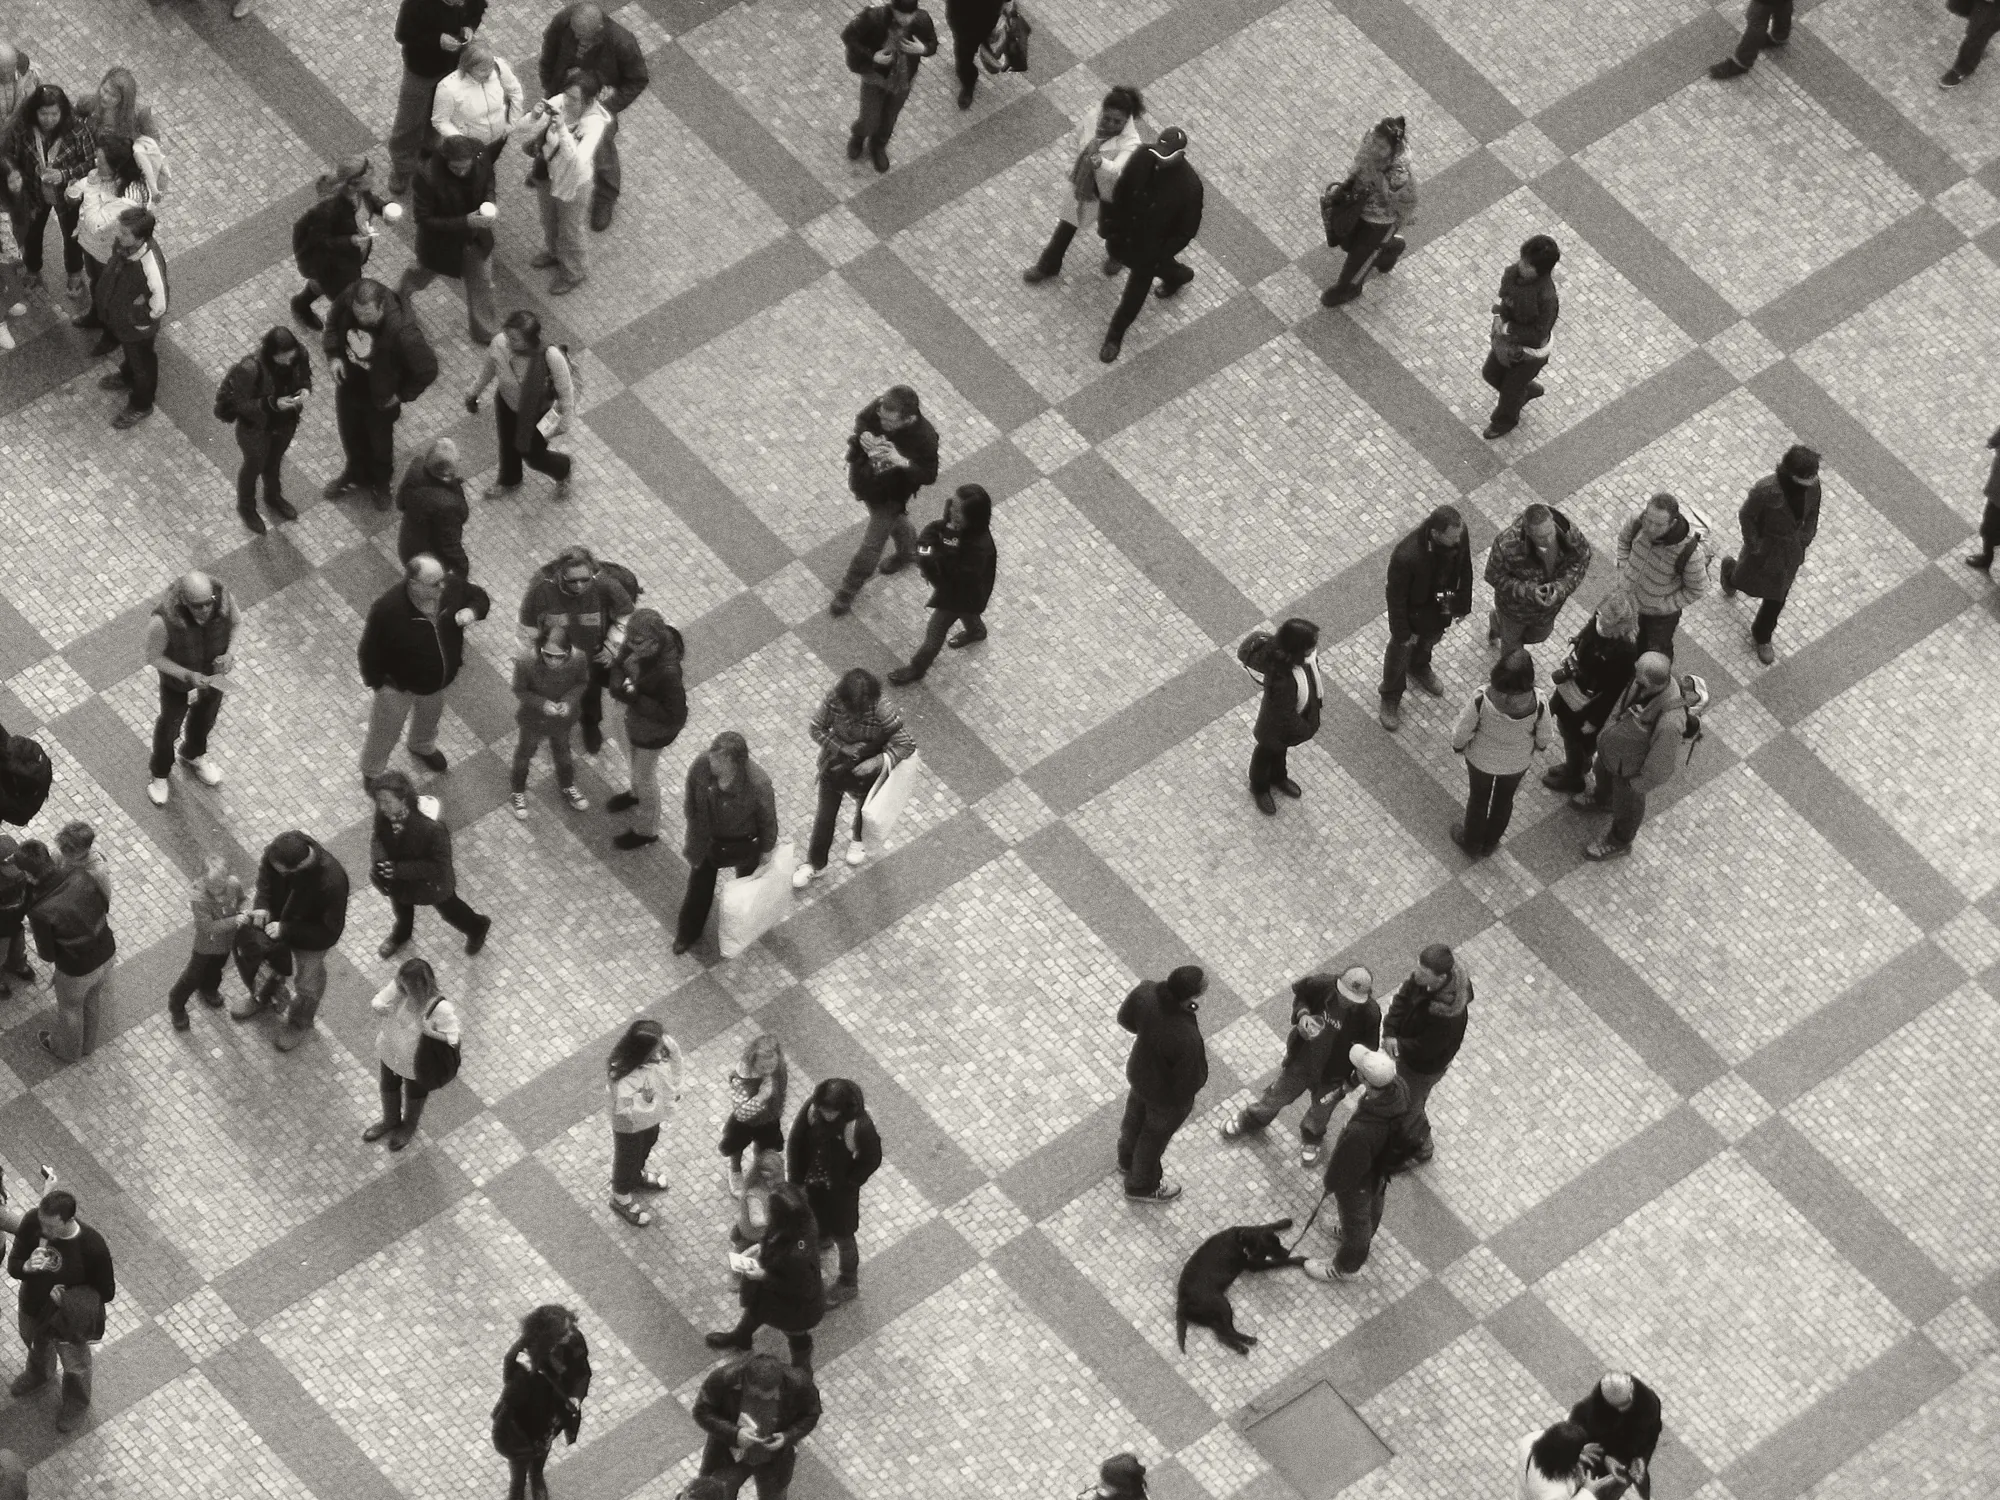
It has to learn to walk through us
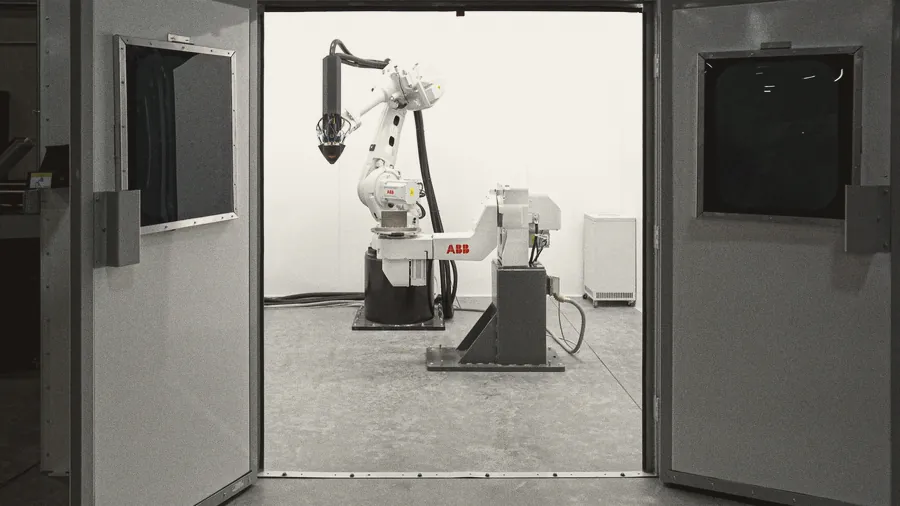
Crowds, kitchens, workshops, warehouses: robots are heading into places people already know how to move through, and people are the ones who can show them the way.
04 · Who it is for
Four ways in.
Learners
Start with a guided challenge and finish with a certificate.
BasicsBuilders
Take on paid challenges and build a record of signed, judged work.
ProtoResearchers
Run reproducible challenges, with grants and co-authorship.
ResearchCompanies
Fund a challenge and get back tested, licensed answers.
Enterprise
05 · Compute
GPU time for training and simulation.
Rent GPU instances with prepaid credits in USDC, in 10, 50 or 100. SSH keys only, billed only while an instance runs.
Live, limited at launch
06 · $NEO
The thread through it all.
$NEO pays for skills and assets, rewards makers, gives holders a say in how the lab runs and lowers challenge fees. Companies fund challenges in ordinary money and the fees convert to $NEO. There are no inflationary emissions.
Live
Nothing on this page is financial advice.
07 · Status
What is real today.
Live
- Lab sign-up, with the first challenges soon
- Compute, limited at launch
- $NEO
- Ten open-source forks on GitHub
In development
- Studio: a browser simulator with templates for pick and place, navigation, mapping, perception and reinforcement learning
Planned
- A library of skills, worlds, datasets and evaluation packs, with royalties to makers
- Later: design a robot's brain without code and have it delivered in certified hardware
The way you were shown.
Patiently, hands on, more than once. It is still the best way to teach anything, robots included.
Show a robot how.
Holding an egg without breaking it is something a robot has to be shown. Sign in with Google or GitHub and pick your first challenge when the agenda opens.